PRANESH G A · COIMBATORE, INDIA
Building for
autonomy.
I build robotics software, machine vision systems and embedded hardware. My next focus is autonomous mobile navigation, SLAM and AI for robots.
OPEN TO ROBOTICS & SOFTWARE INTERNSHIPSBannari Amman Institute of Technology · Class of 2029
SELECTED PROJECTS / PORTFOLIO01 / 04
EXPERIENCE TeamBIT · DD Robocon 2026COMPETITION e-Yantra 2026–27 · two 100/100 Strata tasksDIRECTION Mobile navigation · SLAM · Robotics AI
01 / SELECTED WORK
Ideas, made tangible.
Robots, vision and embedded hardware.
Software people can use.
Explore project ↗One workspace. The whole team.
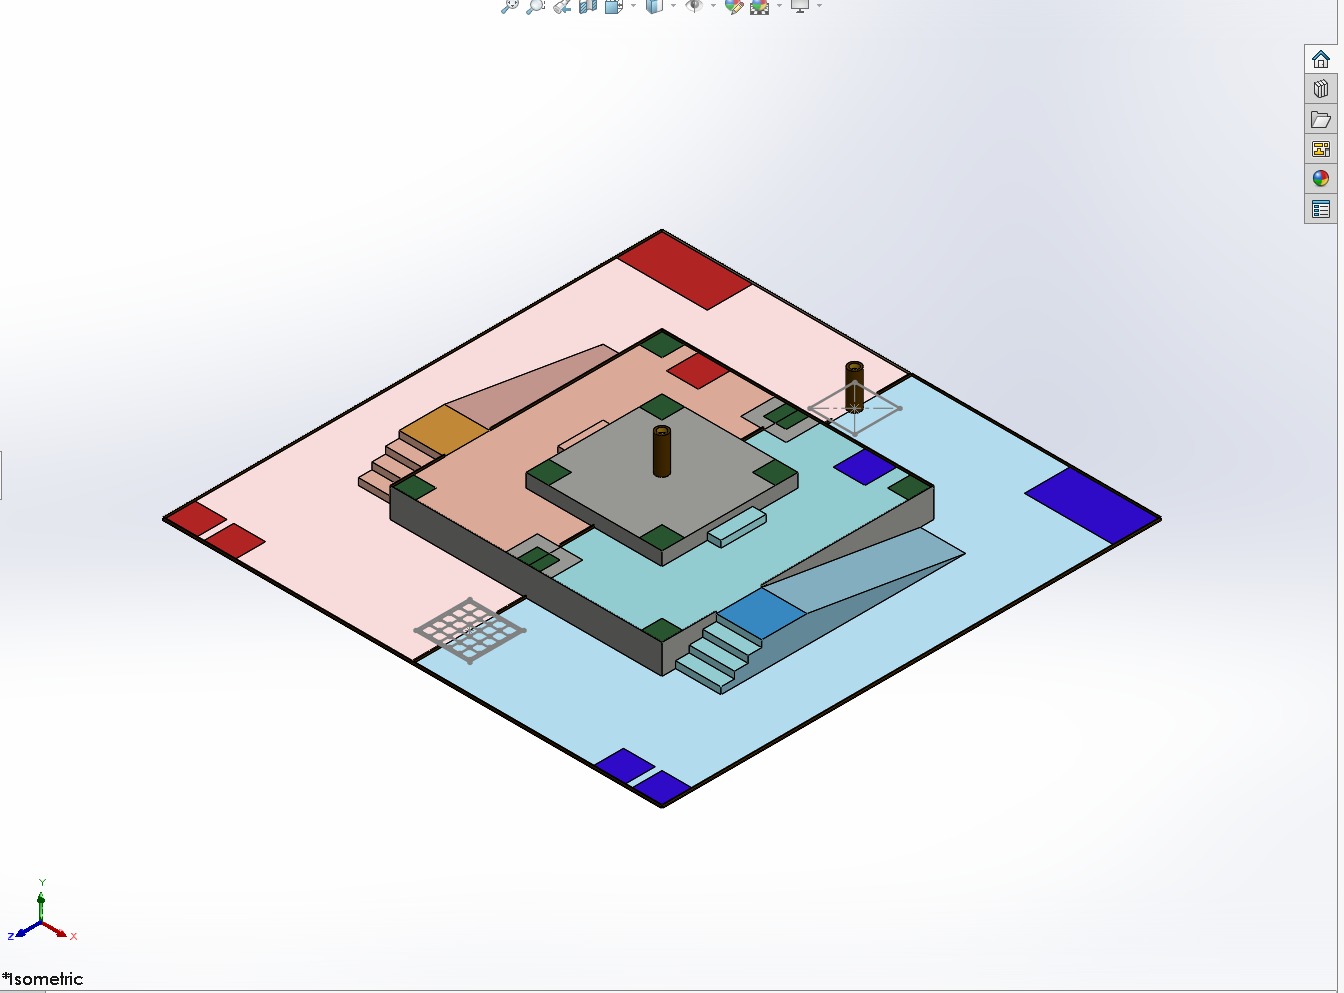
A shared workspace for Mechanical, Electrical, and Software teams — with work logs, maintenance, meetings, files, and arena exploration.
 Explore project ↗
See the object. Keep the track.
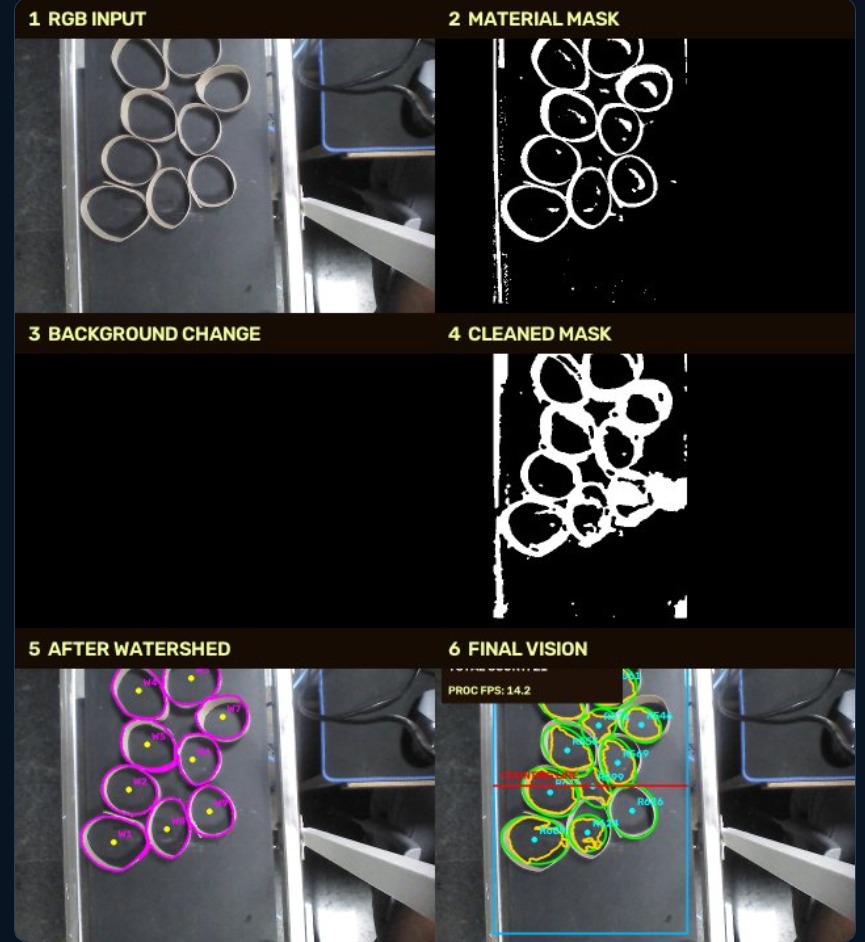
Conveyor ring inspection with shape checks, temporal tracking, and direction-aware counting, using an Orbbec camera adapter.
Explore project ↗Sashtii Designer Boutique.
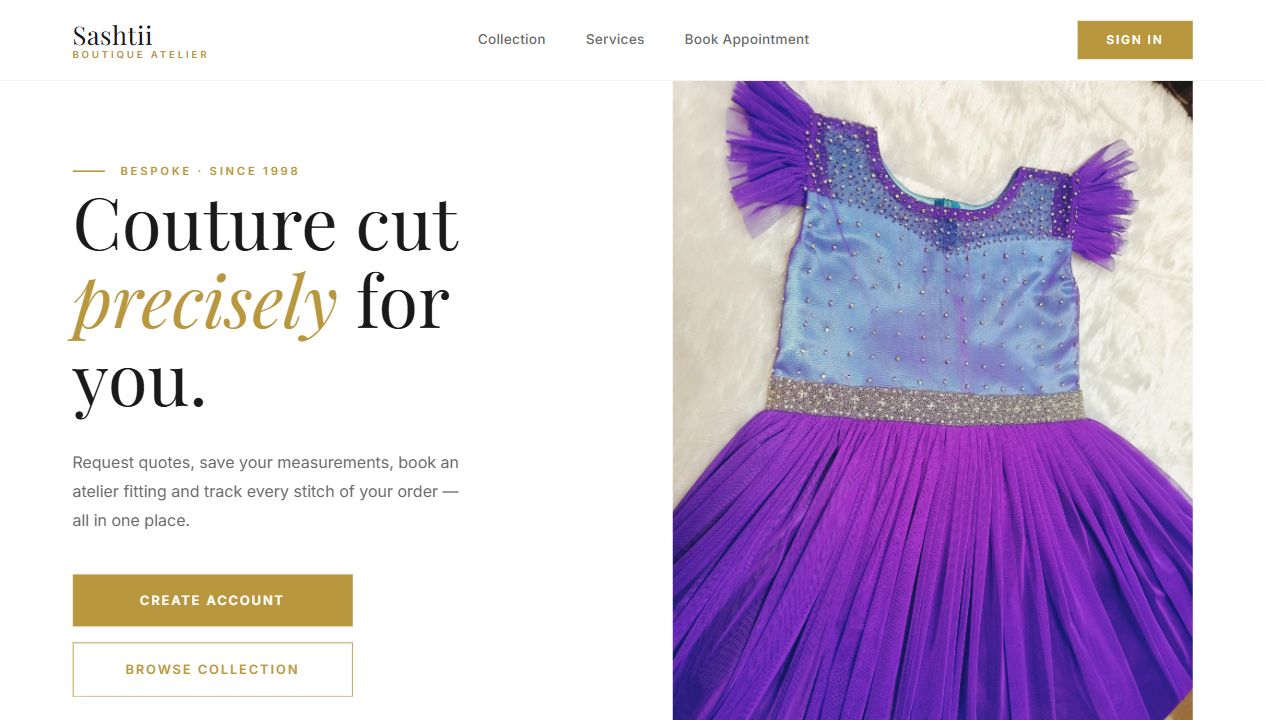
A boutique frontend with collection browsing, quote and appointment forms, customer screens, and an admin interface.
Explore project ↗From invoice to payment.
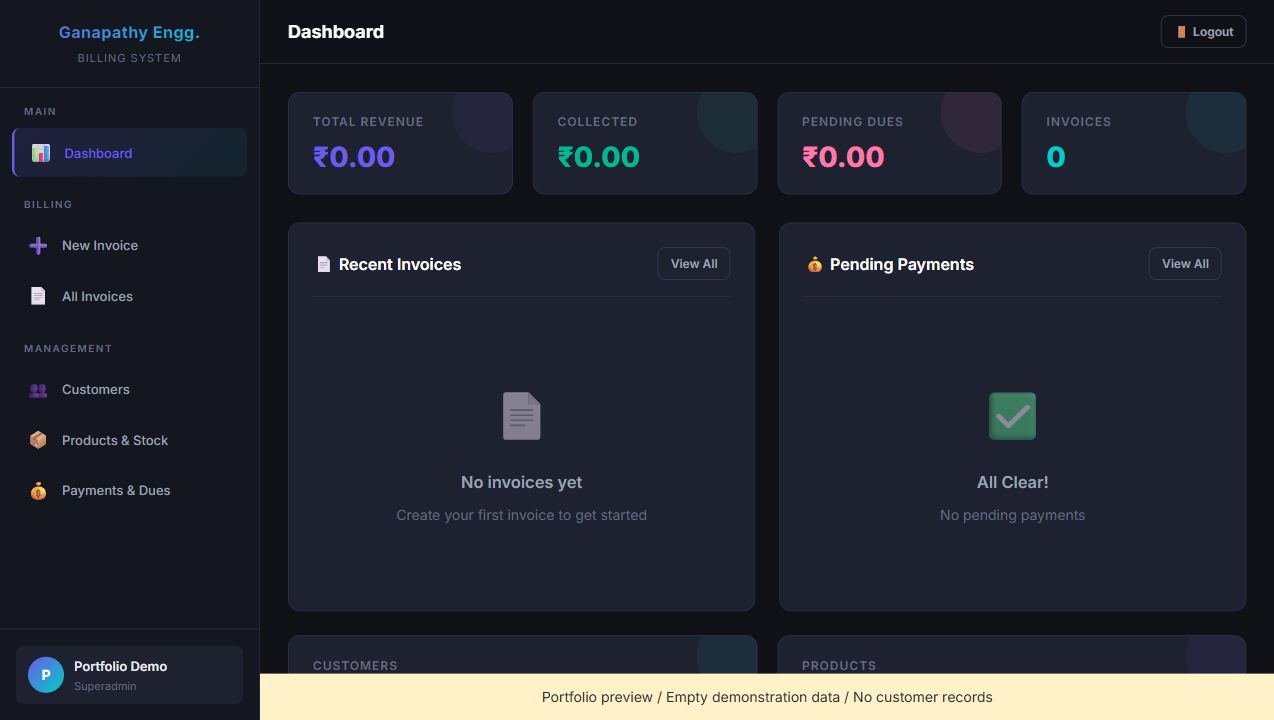
Billing software for Ganapathy Engineering Works, bringing invoices, customers, product stock, payments, and reports into one application.
Explore project ↗Maze solver, on one board.
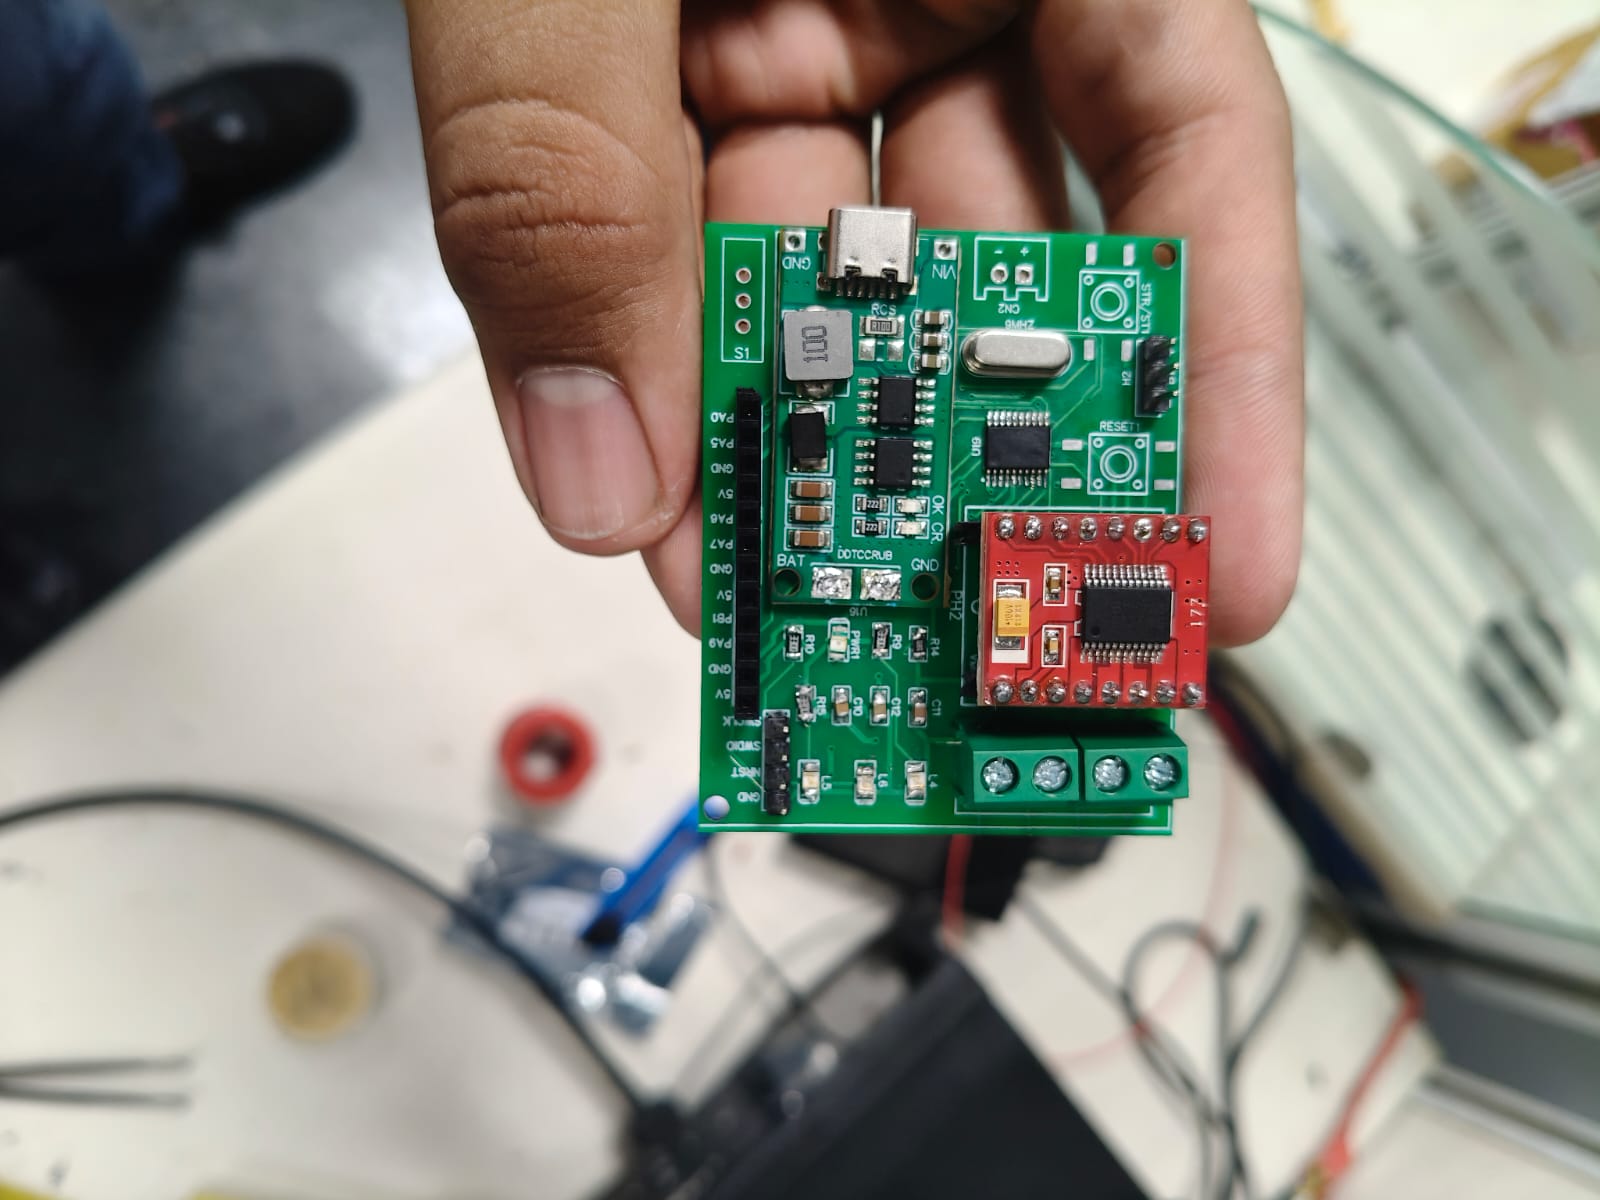
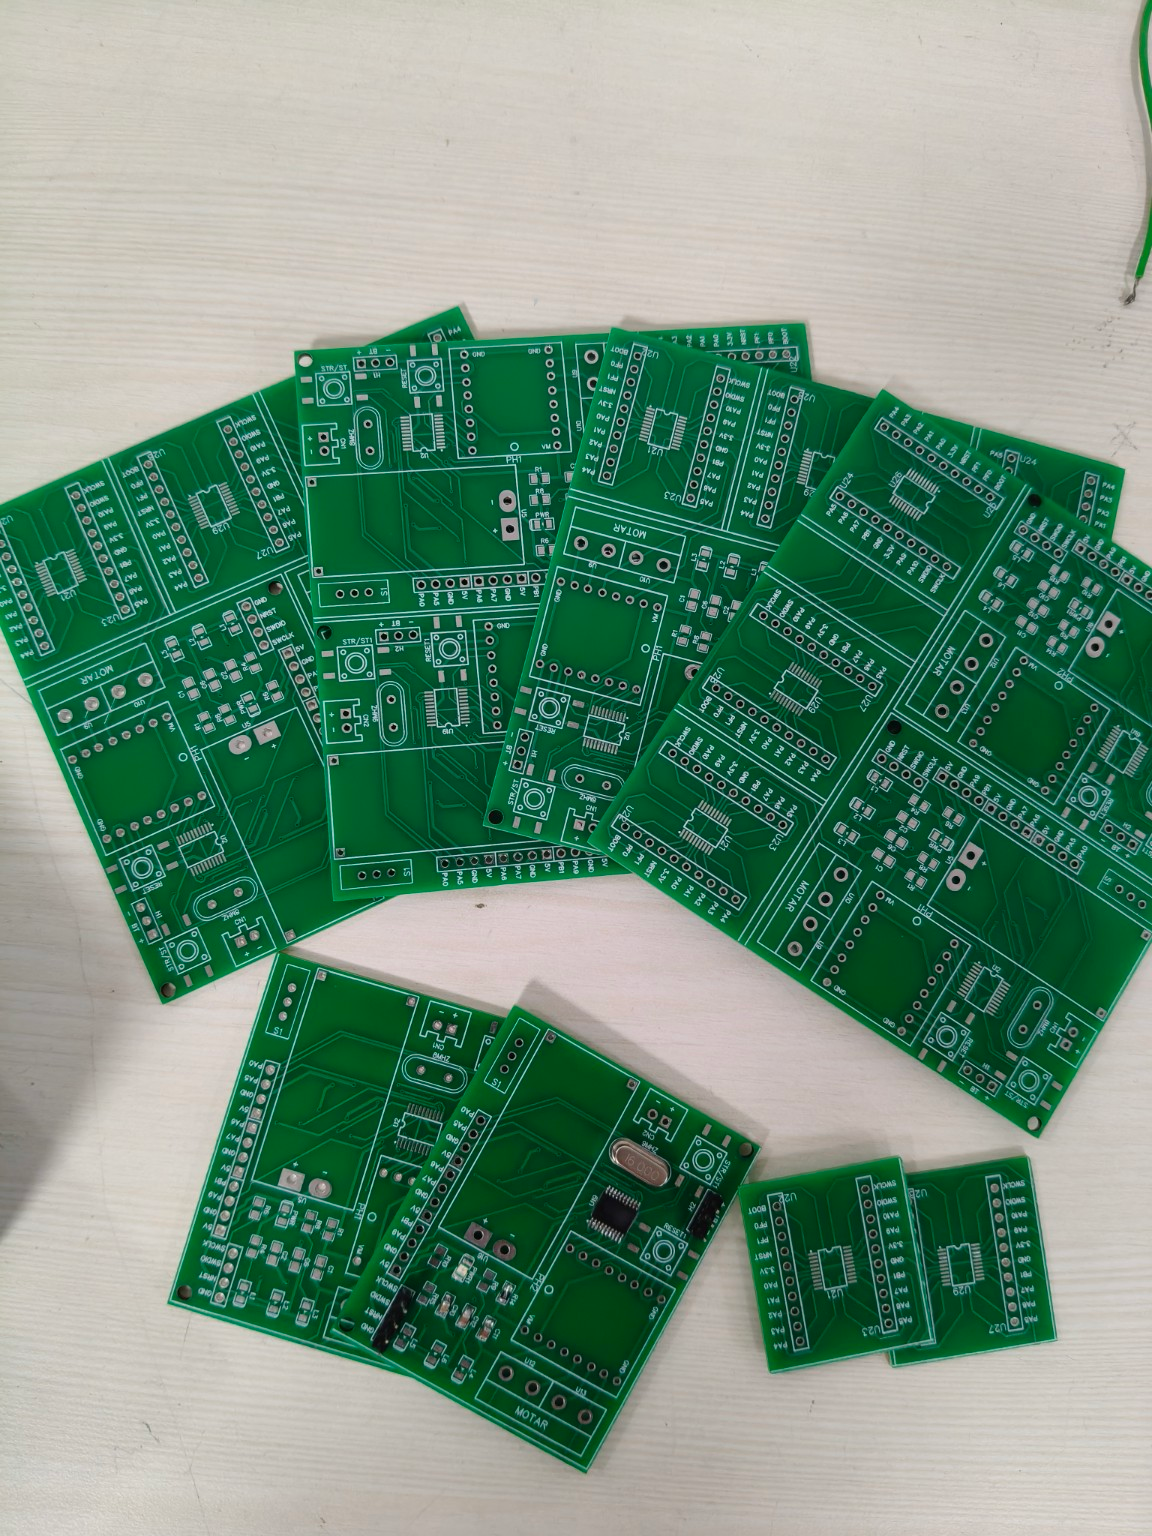
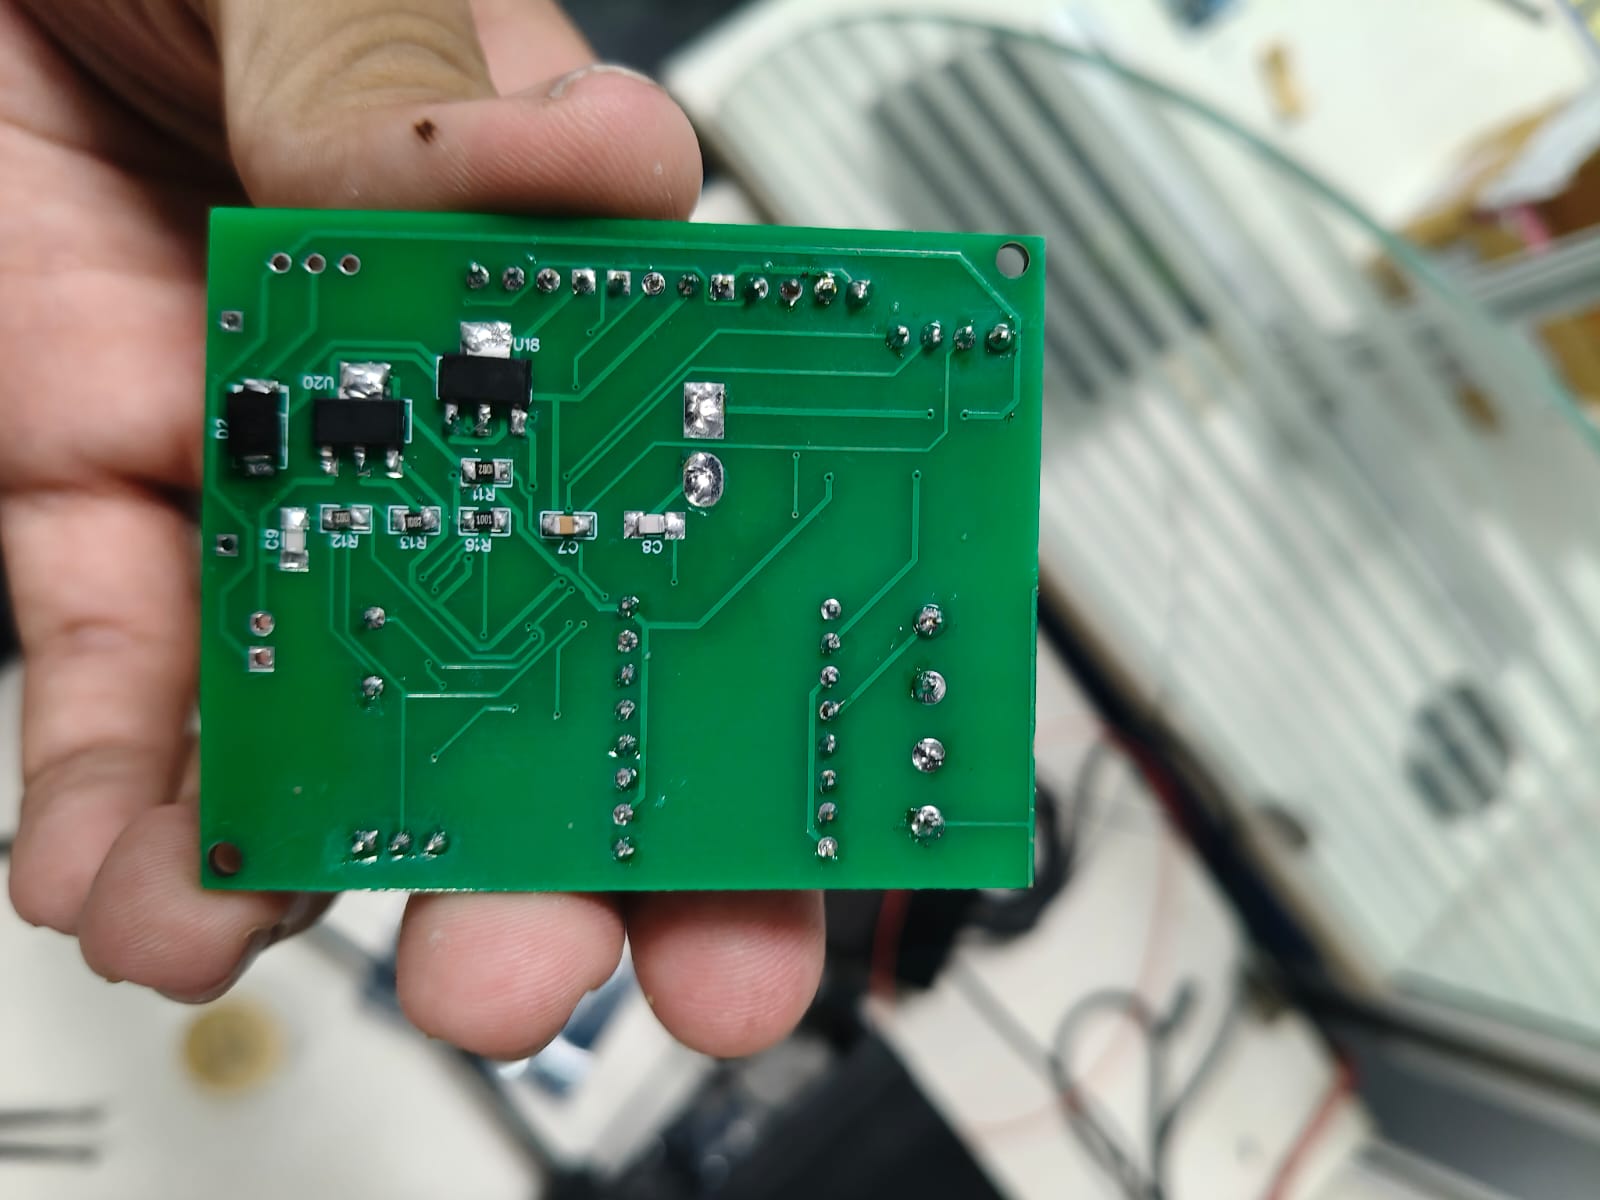
A custom two-layer STM32 board developed with Pranesh S for a maze-solving robot. The supplied photos show fabricated boards and an assembled prototype.
 Watch the software demo ▶
Six axes in motion.
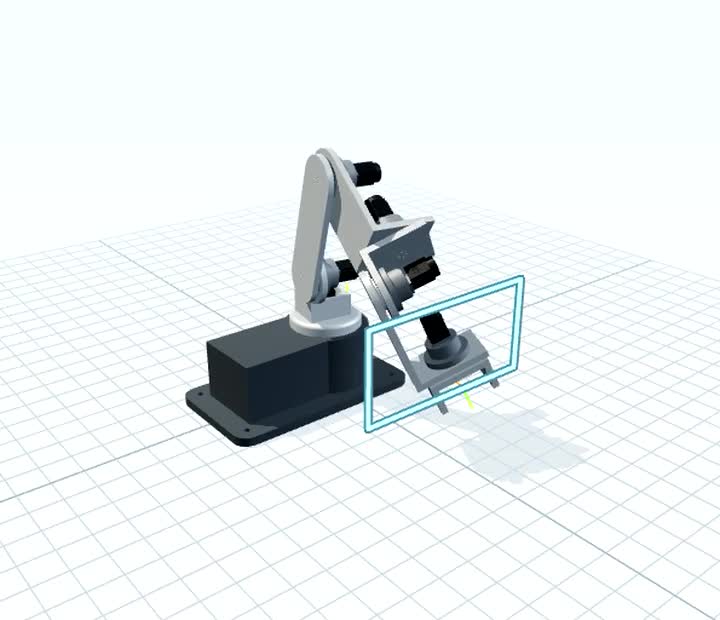
I built Trace Axis Studio, a browser-based workspace for CAD inspection, six-joint motion, keyframe playback, and kinematic path exploration. Watch a recording made in the software.
Mobile robotics.
Details coming soon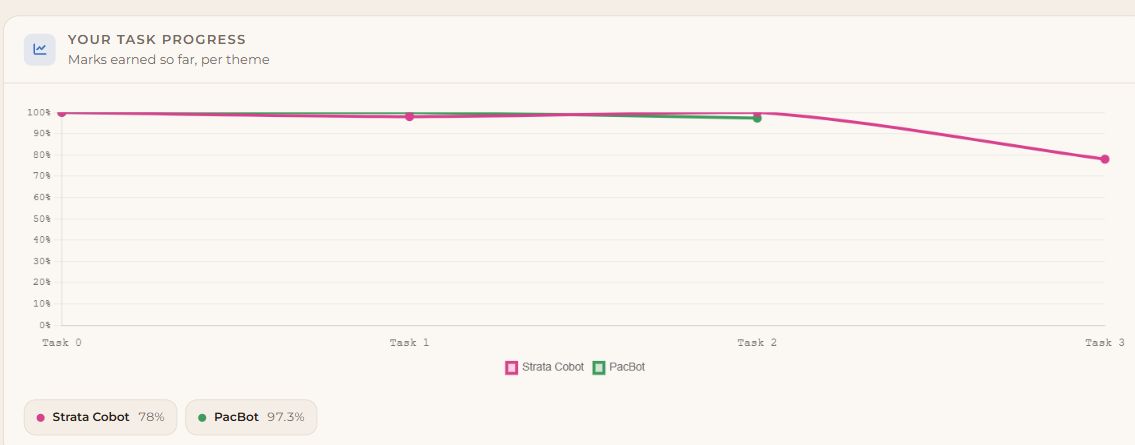
e-Yantra progress.
With team eYRC#3809, I’m competing in the 2026–27 e-Yantra Robotics Competition. The portal shows 100/100 for Strata Cobot Tasks 0 and 2, with more work ongoing.
Follow the project ↓02 / PROJECT FILMS
A closer look.
Watch real project footage, robot motion,
and an arena study.
Machine vision conveyor counter — actual project recording supplied by Pranesh G A. See ring detection and counting in motion.
03 / BEHIND THE BUILD
How I approached it.
The problem, the implementation,
and the current scope.
ROBOCON 2027 / TEAM SOFTWAREOne workspace. The whole team.
+
The problem
A robot build spans several disciplines. Team updates, maintenance issues, meetings, and reference files need a shared place.
What I built
The Team Crimson workspace separates sector workflows and brings daily work logs, maintenance tracking, meetings, notifications, and shared files together. A 3D arena viewer adds field context.
Arena preparation
I collaborated with Sanjay Kumaar M on the Robocon 2027 arena CAD. The portfolio field study shows scripted TR and BR routes; it is an illustrative visualization, not a tested autonomous controller.
MACHINE VISION / INSPECTIONSee the object. Keep the track.
+
The problem
Counting moving rings means separating detections from persistent objects, especially around overlaps, seams, shadows, and changes in direction.
How it works
Shape validation and material masking identify candidates. Temporal confirmation and tracking preserve identities; direction-aware crossing logic decides when to count.
What I tested
Regression cases cover overlapping rings, stationary objects, seams, shadows, and reverse movement. The existing recordings document local tests. Fully occluded objects remain ambiguous in a single RGB view.
INDUSTRY / BOUTIQUE WEBSITESashtii Designer Boutique.
+
The brief
Bring the boutique’s collections and customer journey into one coherent website, from browsing garments to requesting a fitting.
What I built
I organized the React app into customer and admin layouts, with collection browsing, quote and appointment forms, profile screens, customer management, and product screens.
Current scope
The checked-in source demonstrates the frontend experience. Several admin areas remain placeholders, and form submission is currently a UI demonstration. This case study does not claim a deployed commerce backend.
INDUSTRY / BUSINESS SOFTWAREFrom invoice to payment.
+
The workflow
Customer and product records feed invoice creation. Line items, GST, payments, and outstanding dues connect the billing workflow.
What I built
The Flask source separates billing, customers, products, payments, reports, and administration into modules, backed by SQLAlchemy models and reusable templates.
What you are seeing
Screens are rendered from the actual project templates with empty demonstration data. They show the dashboard and invoice interface without publishing customer records or financial results.
STM32 / TWO-LAYER PCBA board for a maze solver.
+
What we made
Pranesh S and I collaborated on a custom STM32 board intended for a maze-solving robot. The two-layer PCB brings the microcontroller and robot-facing connections together in a compact layout.
From design to hardware
The photos show multiple fabricated boards plus an assembled prototype with power input, programming access, and a motor-driver module. They document physical fabrication and assembly; robot performance and maze results will be added after testing records are shared.
Guidance
Senthilkumar P. and Surya Prakash G.A. guided and mentored us through the project.
SIX-AXIS / SIMULATION SOFTWAREI built Trace Axis Studio.
+
What I made
Trace Axis Studio is my browser-based robot simulation workspace. I built CAD import and inspection, six-joint controls, a keyframe timeline, view and shading tools, and kinematic path exploration. The demo below shows a programmed sequence in the moving viewport.
Watch the software simulation
This recording was captured from the moving robot viewport in Trace Axis Studio. It shows the earlier uploaded articulated robot CAD running a programmed sequence.
Current scope
The recording shows kinematic visualization of the earlier CAD assembly. Quantum V2 CAD can also be inspected in the software, but its joints still need calibration before motion playback. Dynamics and physical robot control are outside this demonstration.
04 / ROBOTICS JOURNEY
Beyond the screen.
Team builds. Competition preparation.
Learning through integration.
DD Robocon · TeamBIT
I participated with TeamBIT in DD Robocon India 2026, working across robot software, electrical systems, and mechanical integration.
Our 18-day build brought a manual pick-and-place robot and an autonomous robot together alongside semester examinations. The work connected design, wiring, programming, testing, and integration.
Read the team build story ↗e-Yantra · eYRC#3809
I’m part of a four-person Bannari Amman Institute of Technology team in the e-Yantra Robotics Competition. We are working across the Strata Cobot and PacBot themes. The portal records the team’s best graded task submissions.
100/100Strata Cobot · Task 0
100/100Strata Cobot · Task 2
100/100PacBot · Task 1
Other recorded marks: Strata Cobot Task 1, 98/100; PacBot Task 2, 97.30/100. The current portal dashboard shows 78% for Strata Cobot and 97.3% for PacBot; Task 3 is ongoing. These are team task marks, not an overall rank or qualification result.
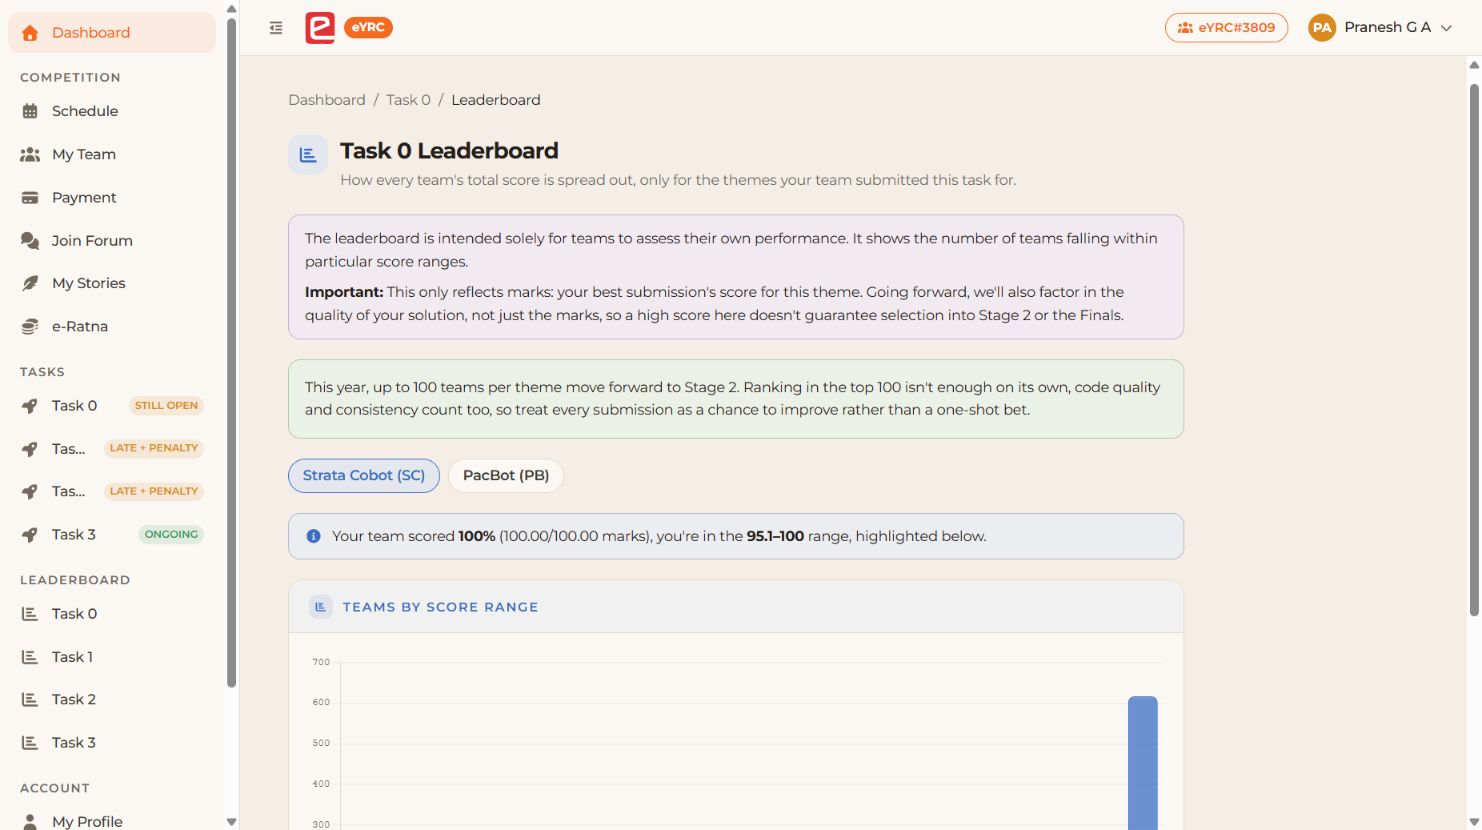
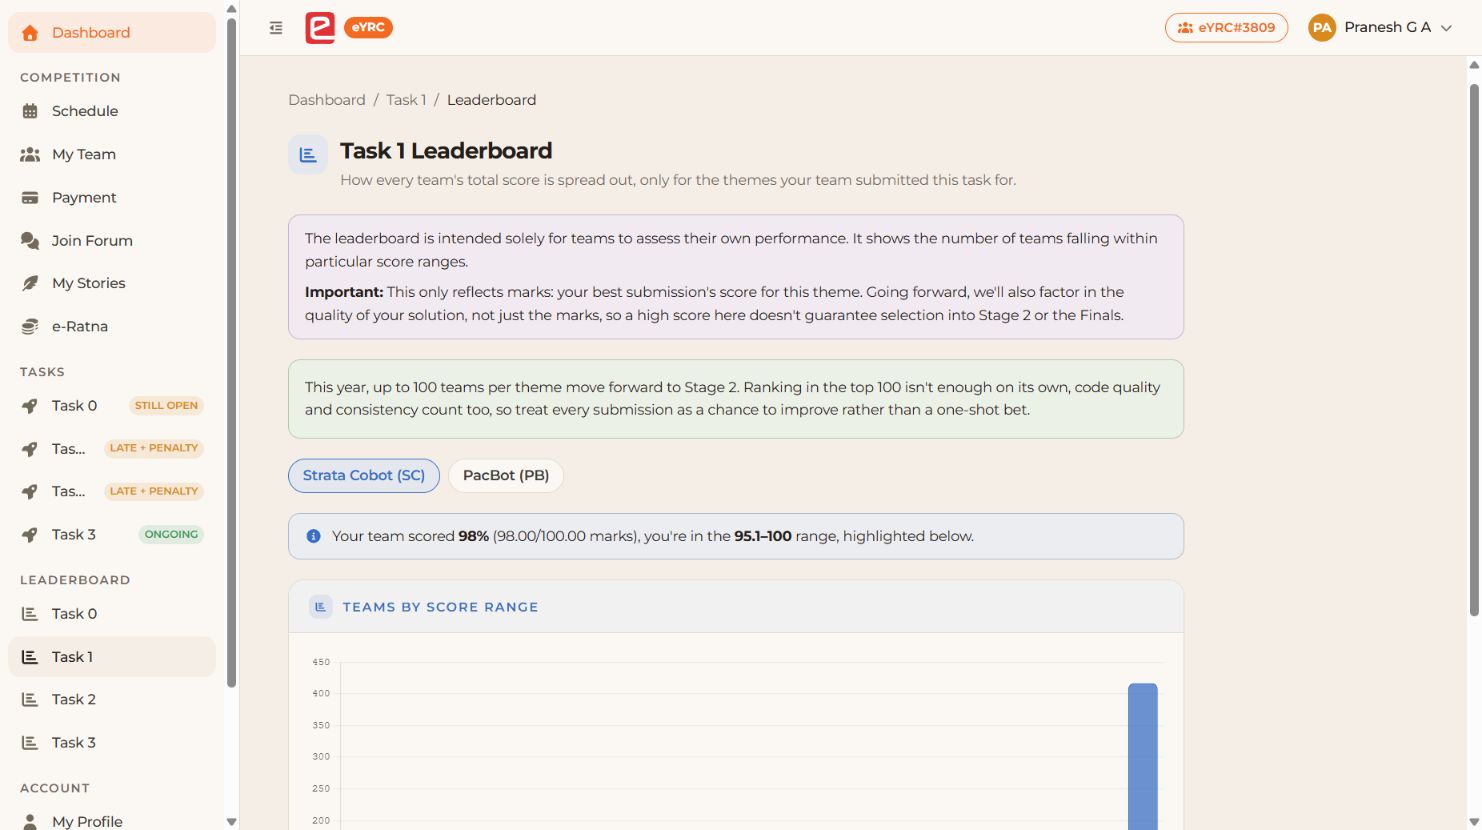
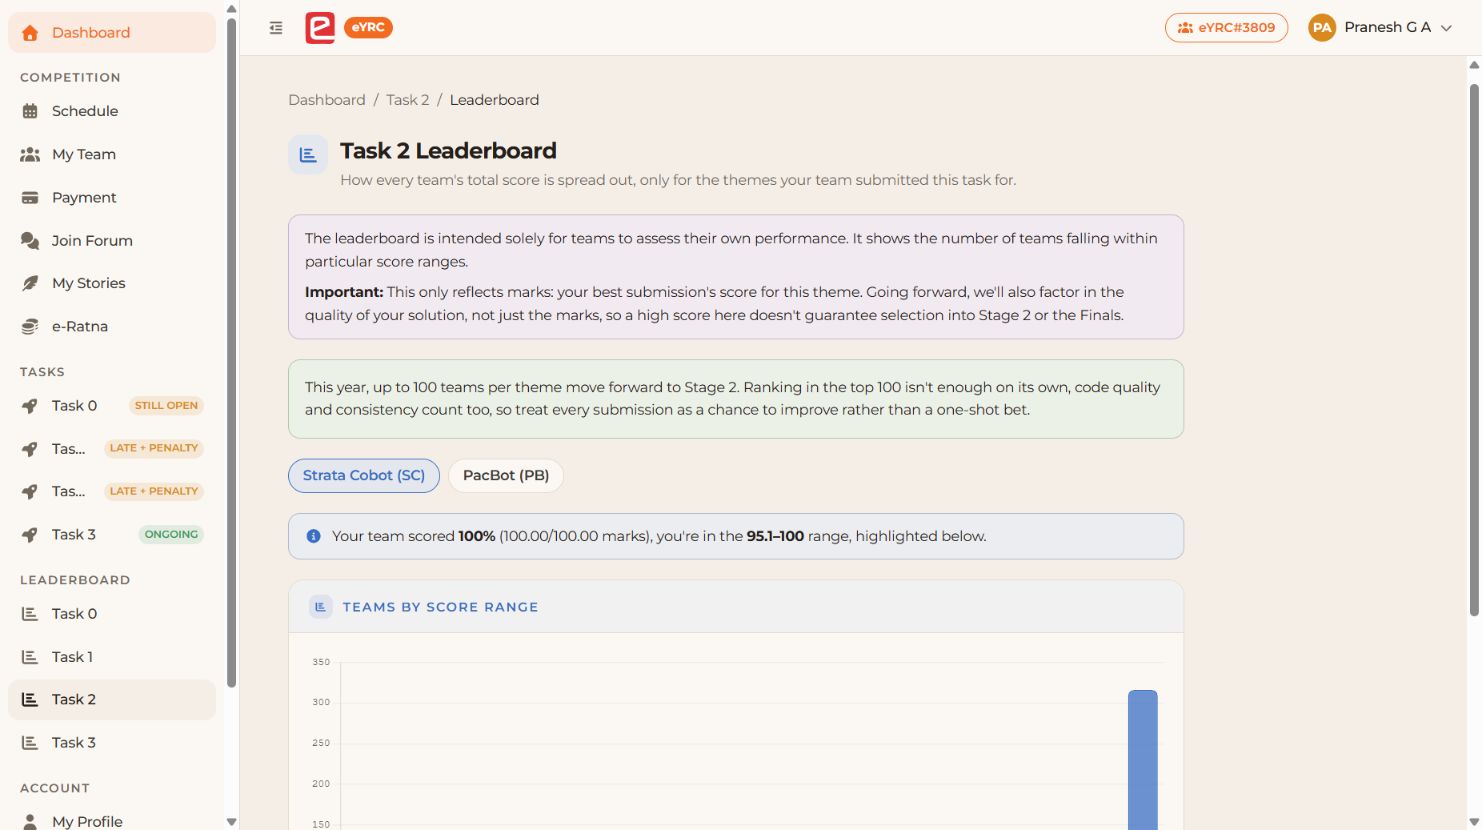
Source: e-Yantra team leaderboard, checked 4 November 2026. The competition evaluates code quality and consistency as well as marks.
Problem statement 26039
I participated in Smart India Hackathon on problem statement 26039. The project brief, my contribution, images and outcome will be added with the supporting documents.
 COIMBATORE, TAMIL NADU
05 / THE PERSON BEHIND THE PROJECTS
Curious by nature.
Hands-on by choice.
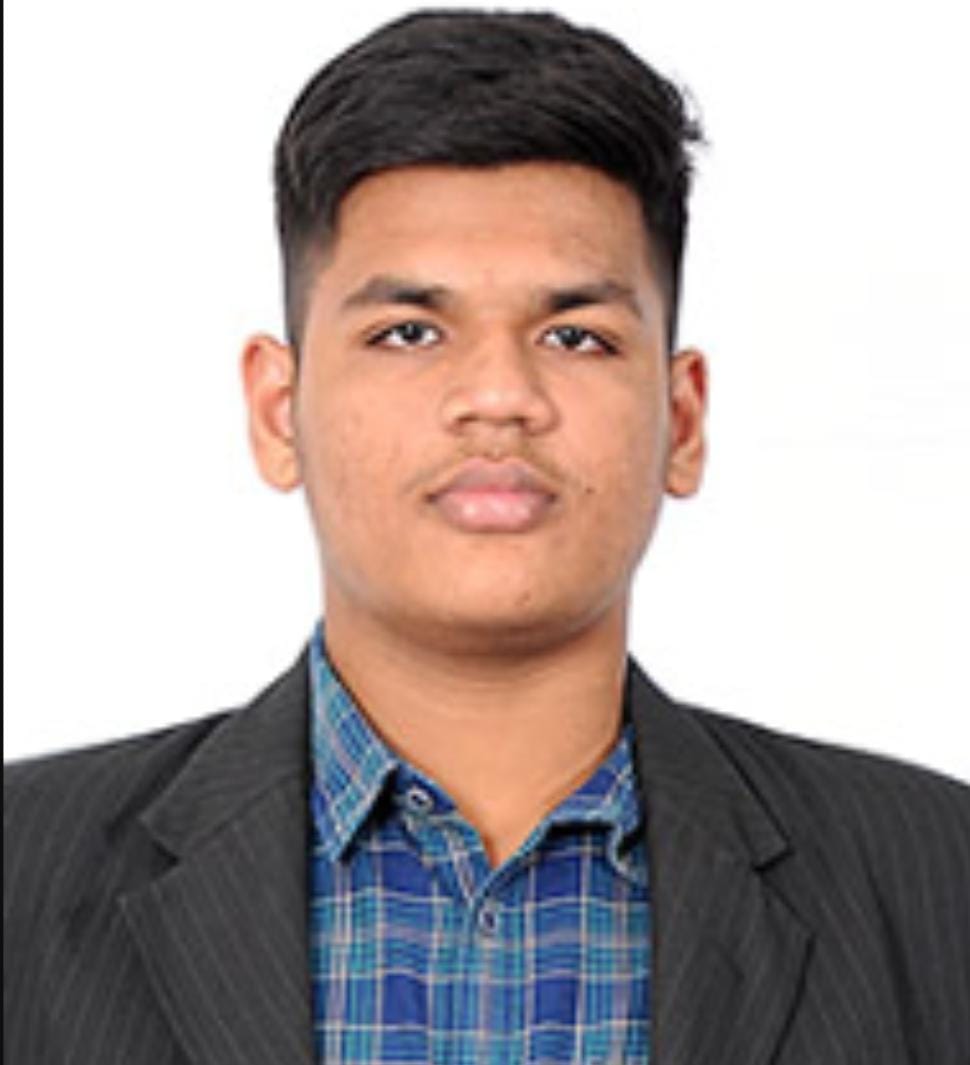
I’m Pranesh G A, studying B.E. Mechatronics Engineering at Bannari Amman Institute of Technology, 2025–2029. I enjoy bringing software, electronics, and mechanisms together.
My direction is autonomous mobile navigation, SLAM, perception, and AI for robotics. Alongside team robotics, I build web interfaces and business software — practical experience in turning a workflow into a usable tool.
EDUCATIONB.E. Mechatronics · 2029
CGPA7.75 / 10
ROBOTICS & EMBEDDEDPython · ROS 2 · Jetson Nano · Raspberry Pi · ESP32 · Arduino
AI & VISIONPyTorch · YOLO · OpenCV
PCB & ELECTRONICSKiCad · EasyEDA
SOFTWAREReact · Flask · Git
OPEN TO INTERNSHIPS & COLLABORATION